Project notes
Multi-agent robot electronics
Custom control boards connecting the robot’s power, sensing, and motion.
- Discipline
- Robotics
- Context
- Bachelor Thesis
- Period
- 2012–2013
- Support
- DIKTI-PKMP
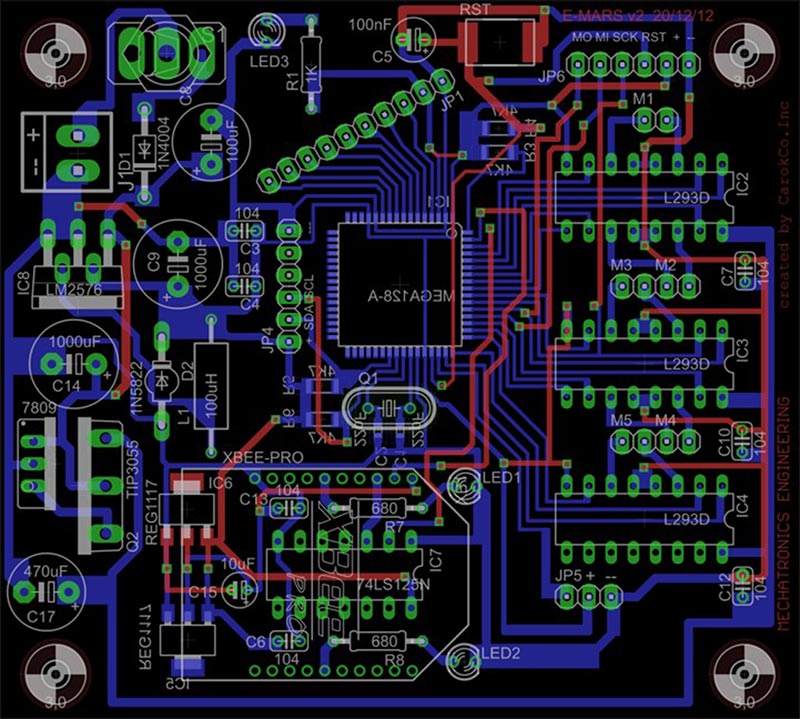
Wiring design


9 images · Select a thumbnail to explore. Original project photographs and illustrations.
The work
I developed three iterations of a control board for the multi-agent robot soccer platform. The electronics brought together motor drivers, power regulation, wireless communication, and debugging connections.
Project contributions & outcomes
- Created schematics, board layouts, and component wiring designs.
- Considered motor current demand, power consumption, and voltage drop.
- Built transmitter and receiver electronics to connect a PC with the robots.
Tools & focus
PCB designMotor
controlWireless communication