Project notes
Multi-agent robot mechanical design
Compact soccer robots refined through three mechanical iterations.
- Discipline
- Robotics
- Context
- Bachelor Thesis
- Period
- 2012–2013
- Support
- DIKTI-PKMP
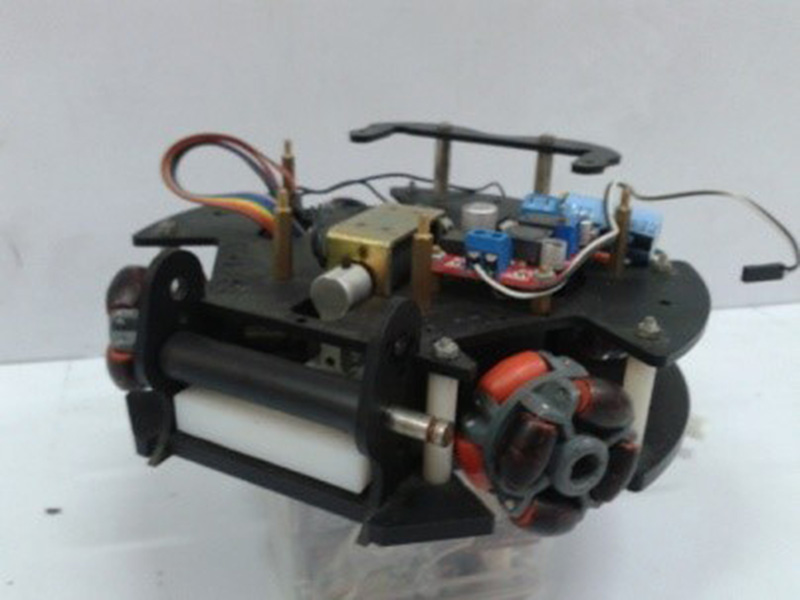
Final design
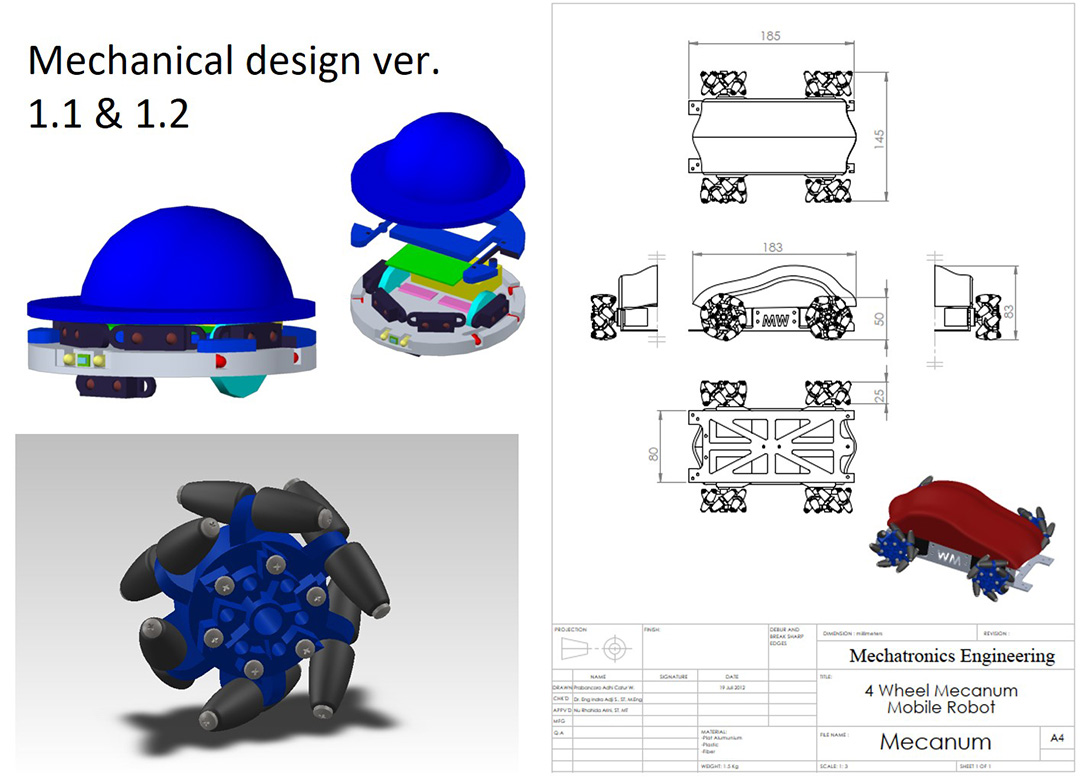
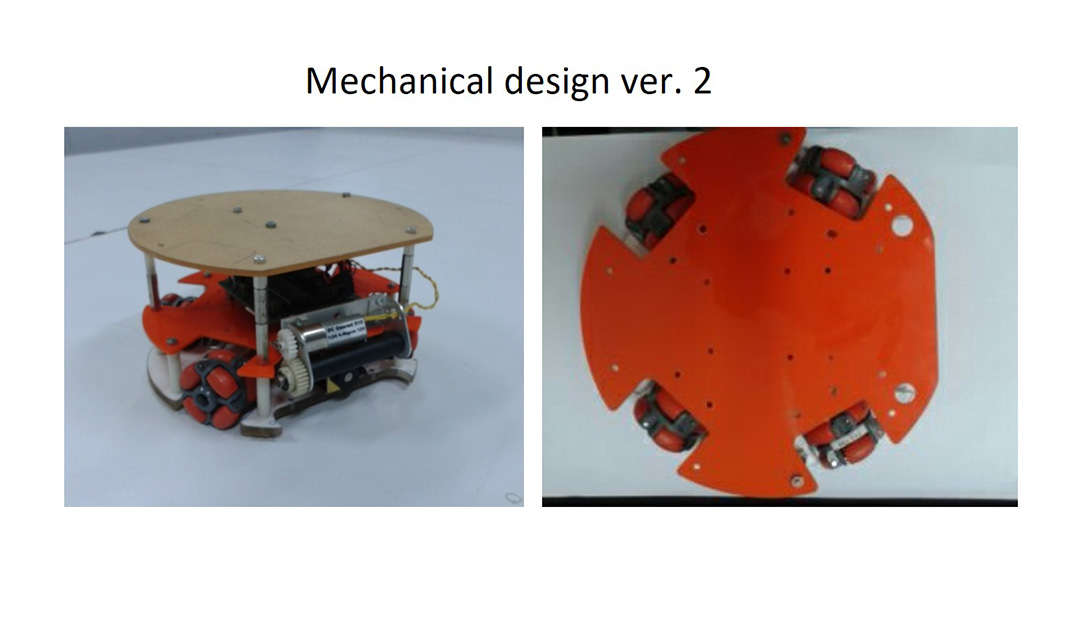
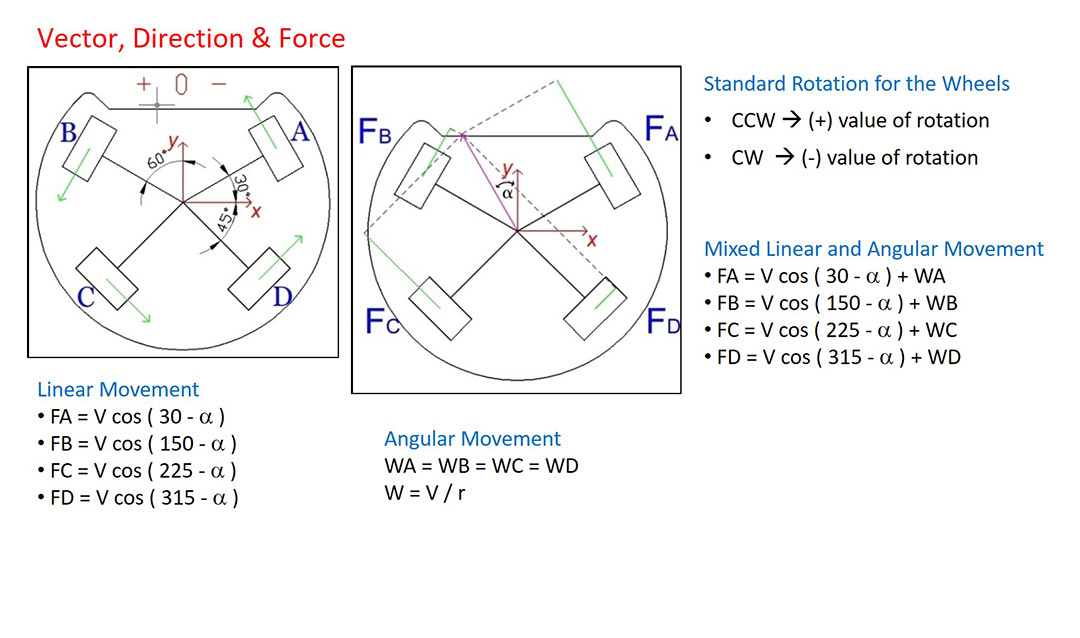
7 images · Select a thumbnail to explore. Original project photographs and illustrations.
The work
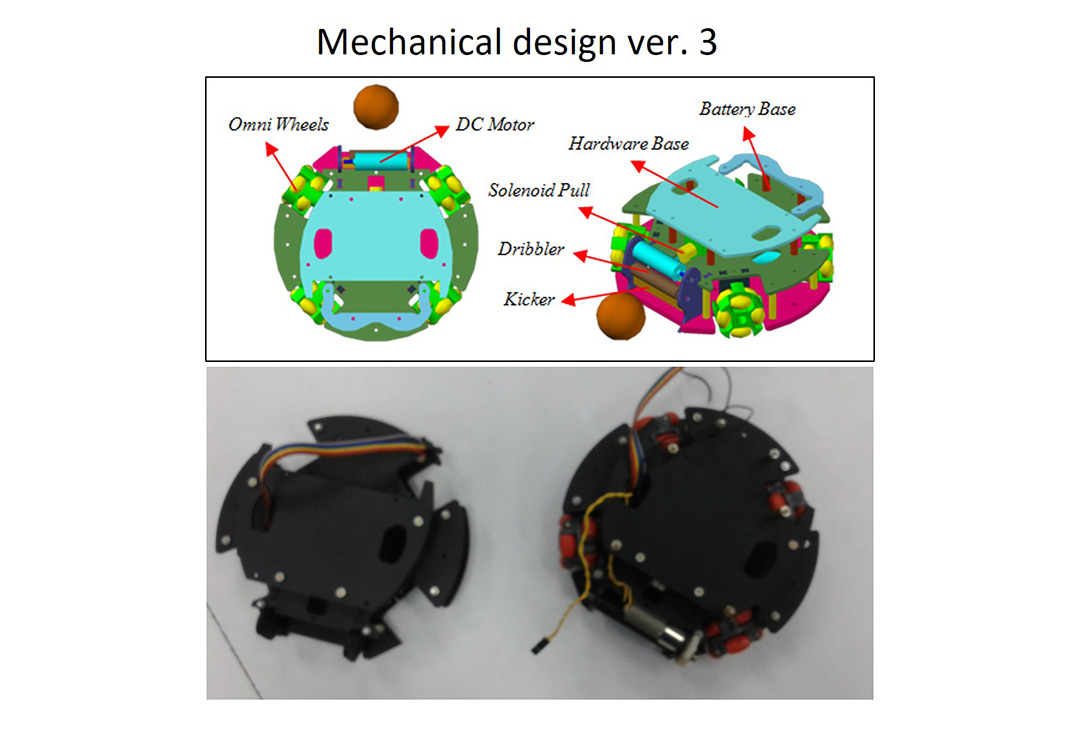
I designed and built a compact holonomic robot platform for multi-agent soccer. The mechanical layout had to fit the drive system, ball-handling hardware, electronics, and battery into a small body.
Project contributions & outcomes
- Developed three versions of the mechanical design.
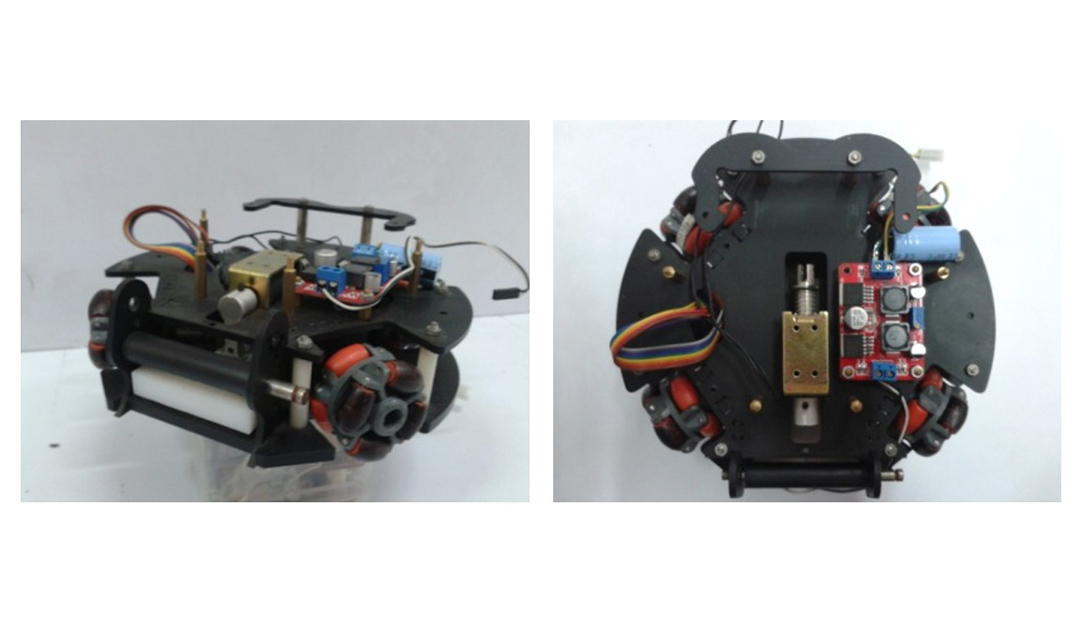
- Integrated four omni-wheel motors, a dribbler motor, and a solenoid kicking mechanism.
- Fabricated and assembled acrylic and aluminum components.
Tools & focus
CADHolonomic drivePrototyping