Project notes
Search and rescue robot
Exploring robot mobility across stairs and uneven terrain.
- Discipline
- Robotics
- Context
- Research
- Period
- 2011–2012
- Support
- DIPA
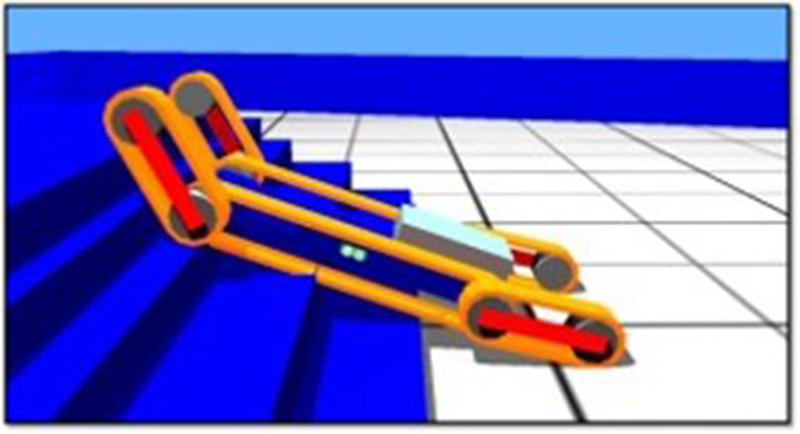
Stepping stair
4 images · Select a thumbnail to explore. Original project photographs and illustrations.
The work
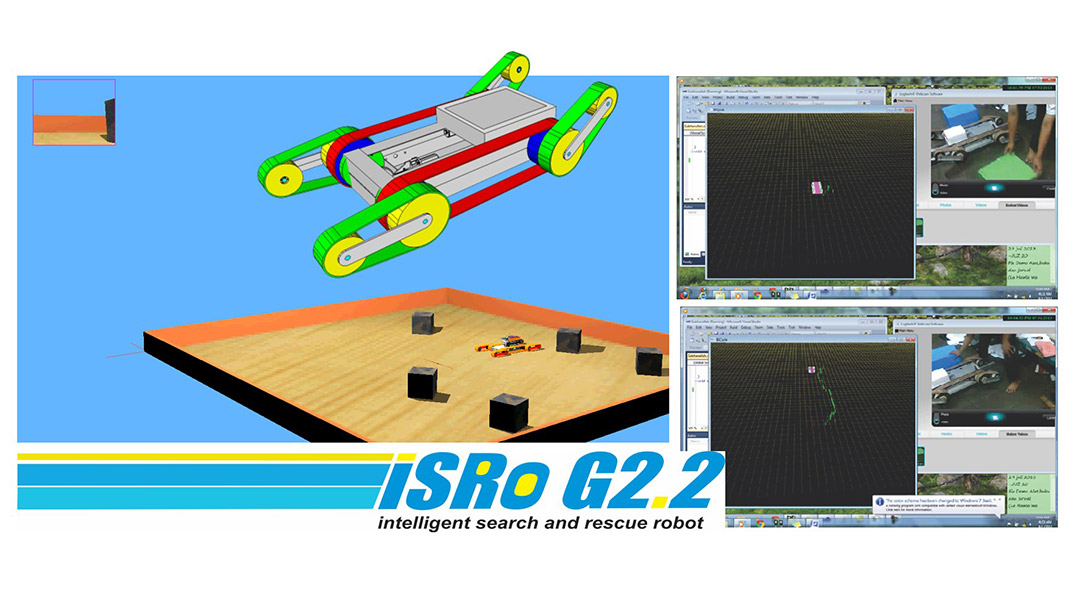
I worked on an intelligent search and rescue robot designed to negotiate difficult terrain. Independent leg movements supported stair climbing, while mapping and obstacle-avoidance methods helped the robot interpret its surroundings.
Project contributions & outcomes
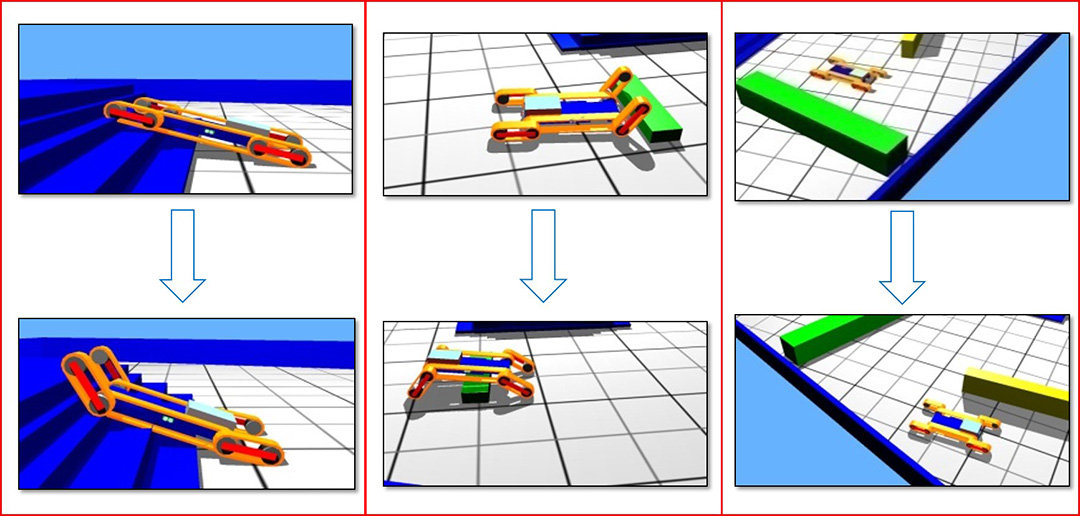
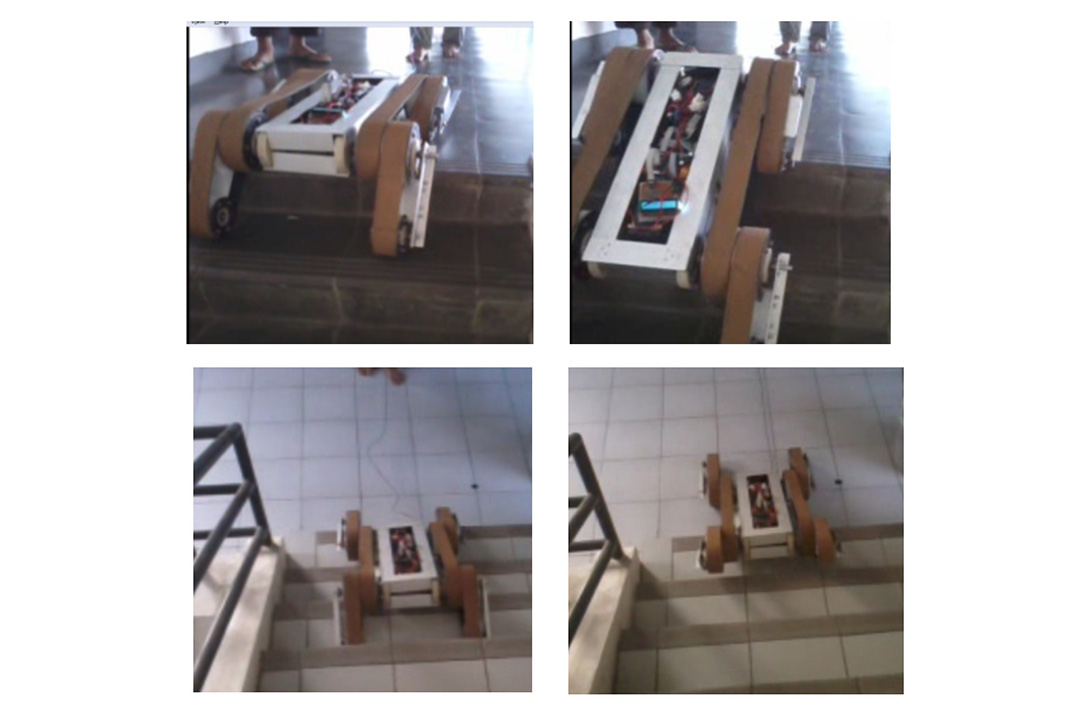
- Investigated independent leg motion for stairs and uneven surfaces.
- Worked with SLAM and fuzzy-logic obstacle avoidance.
- Evaluated behavior in simulation and physical robot experiments.
Tools & focus
SLAMFuzzy logicSimulation