Project notes
Immersive robotic telepresence
Connecting remote spaces through robotics and immersive video.
- Discipline
- Robotics
- Context
- Research
- Period
- 2021–2022
- Support
- UniOGS Infotech
1
6 images · Select a thumbnail to explore. Original project photographs and illustrations.
The work
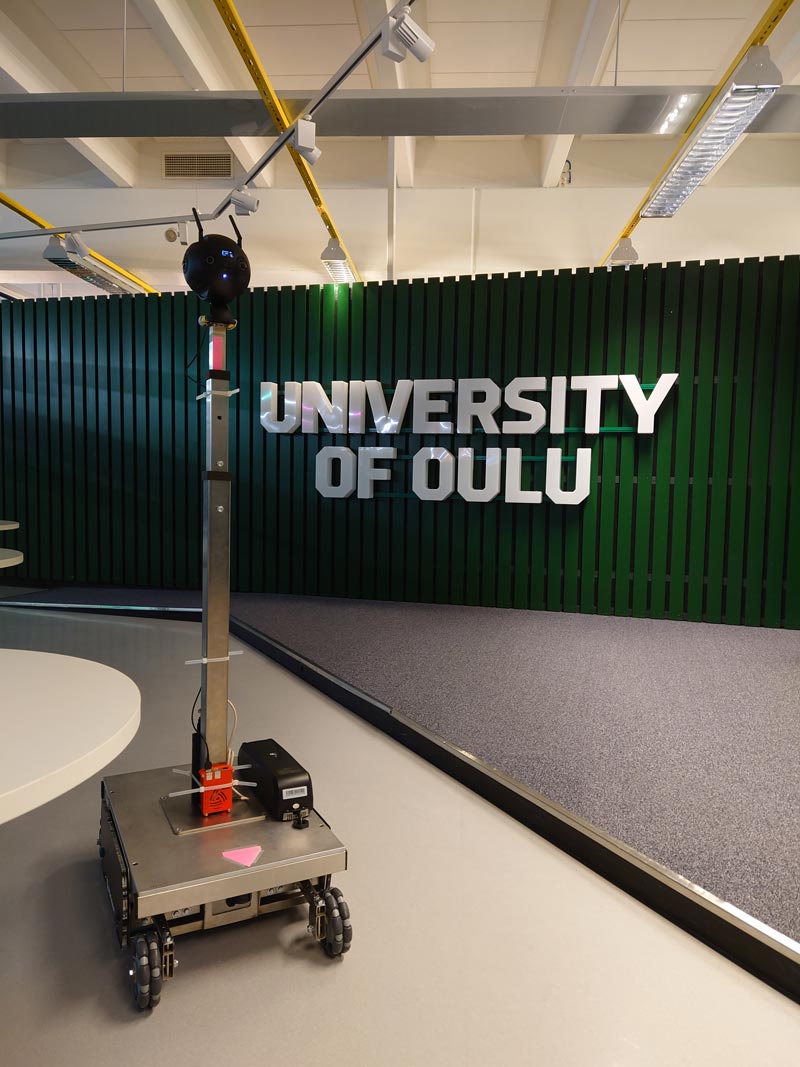
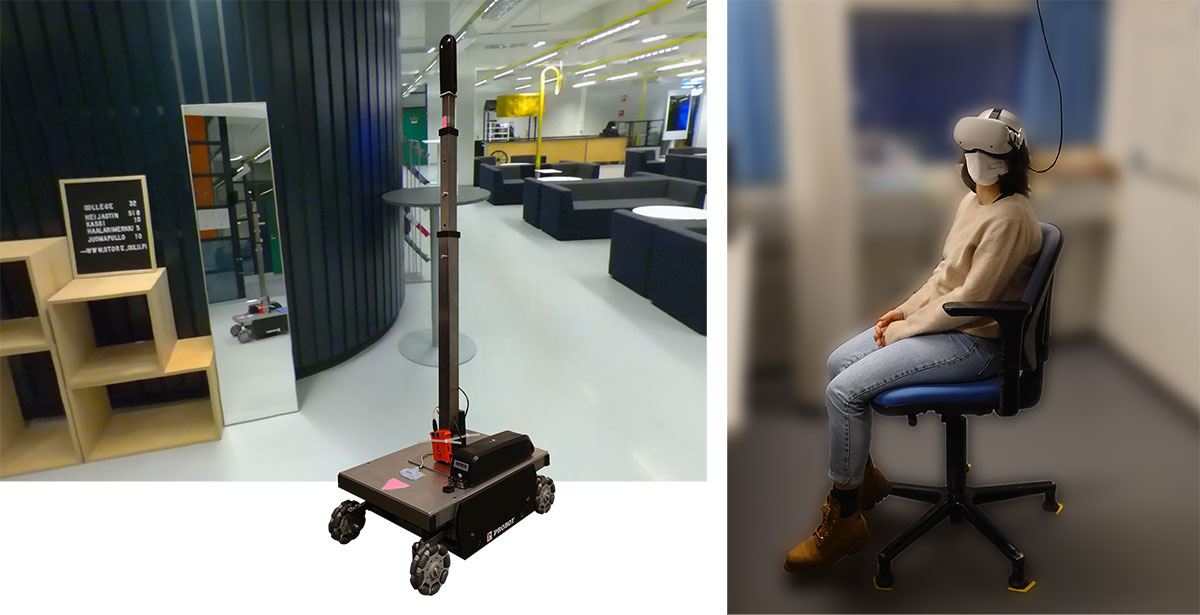
I helped build a telepresence system that lets people experience a remote location through a mobile robot and a VR headset. Working with software, hardware, and design colleagues, I brought a simulated research setup into a physical robot study. The study compared unwound camera rotations with conventional coupled rotations to investigate user comfort.
Project contributions & outcomes
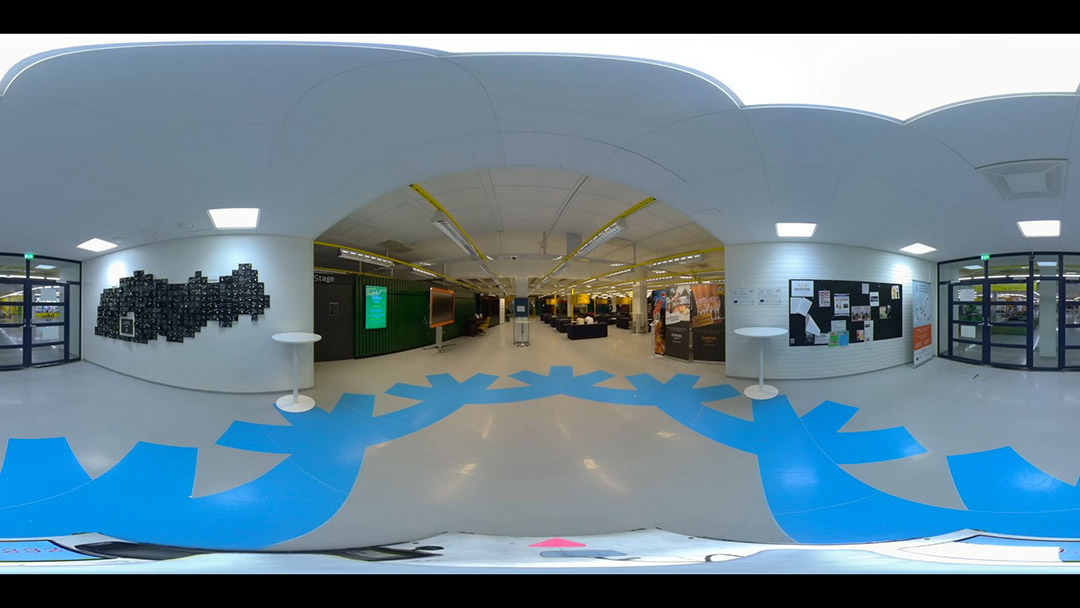
- Integrated 360° camera footage with robot orientation in Unity and ROS 2.
- Worked on video synchronization, communication latency, and image vibration.
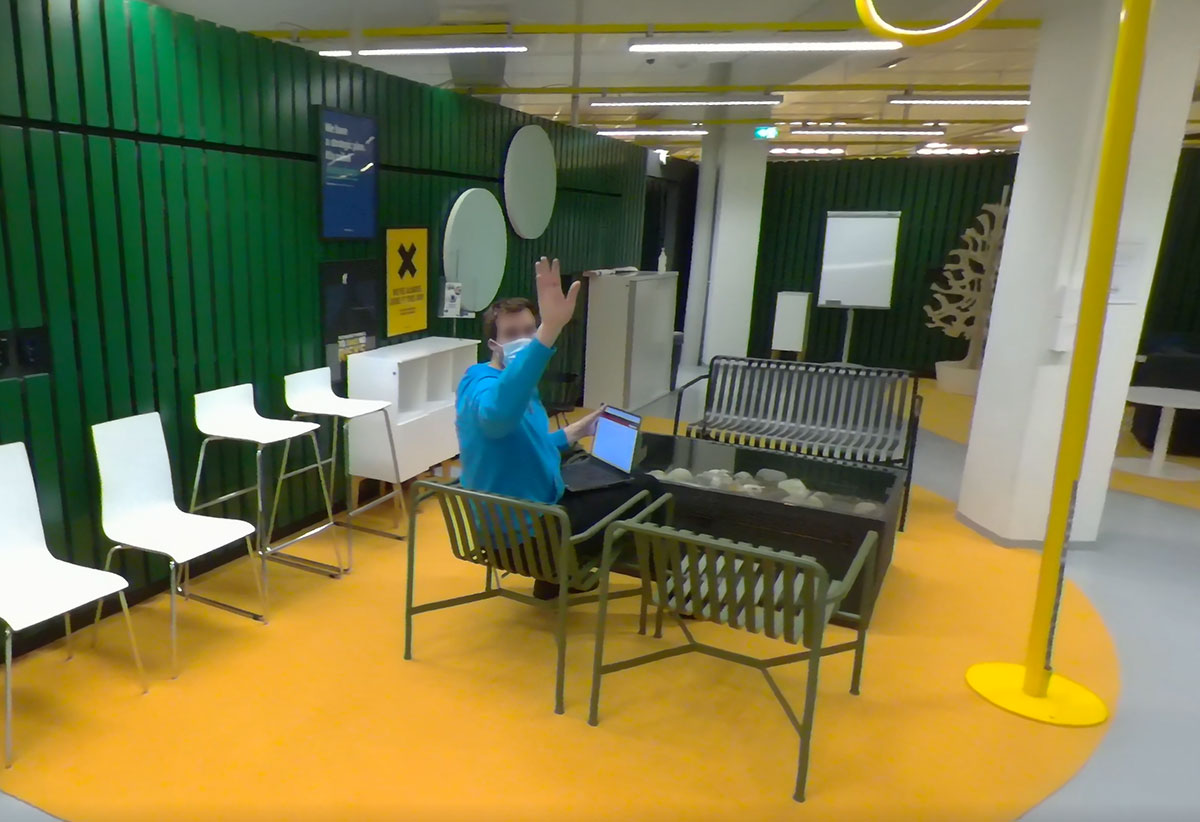
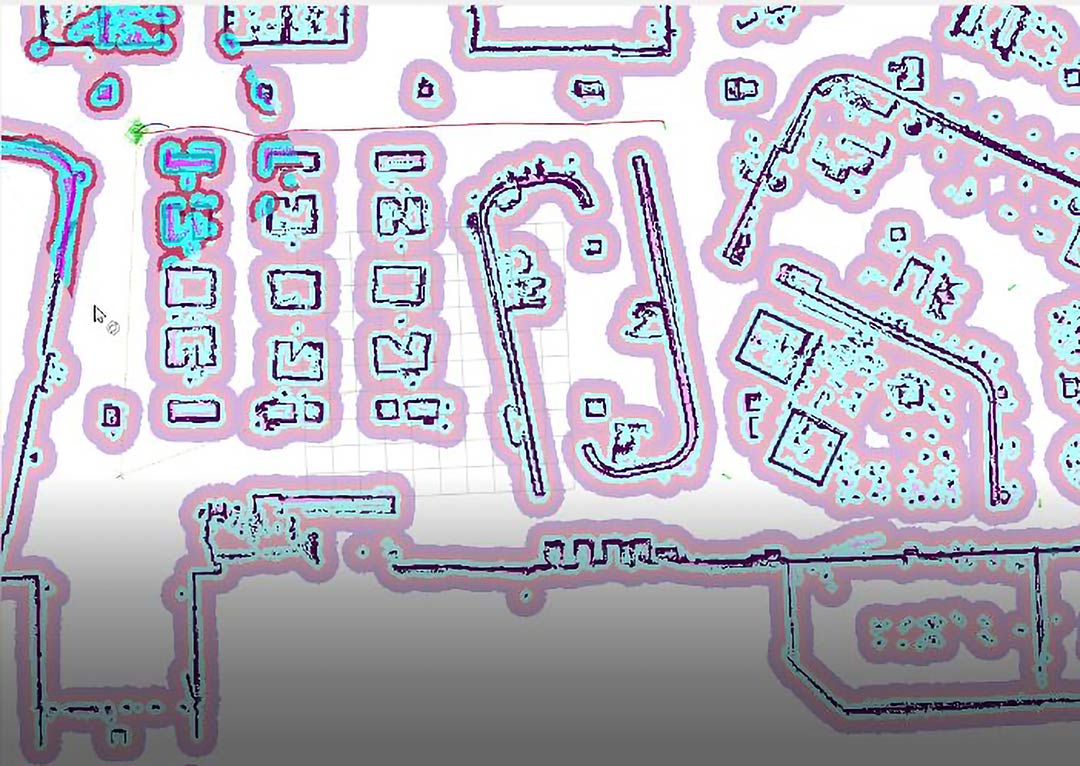
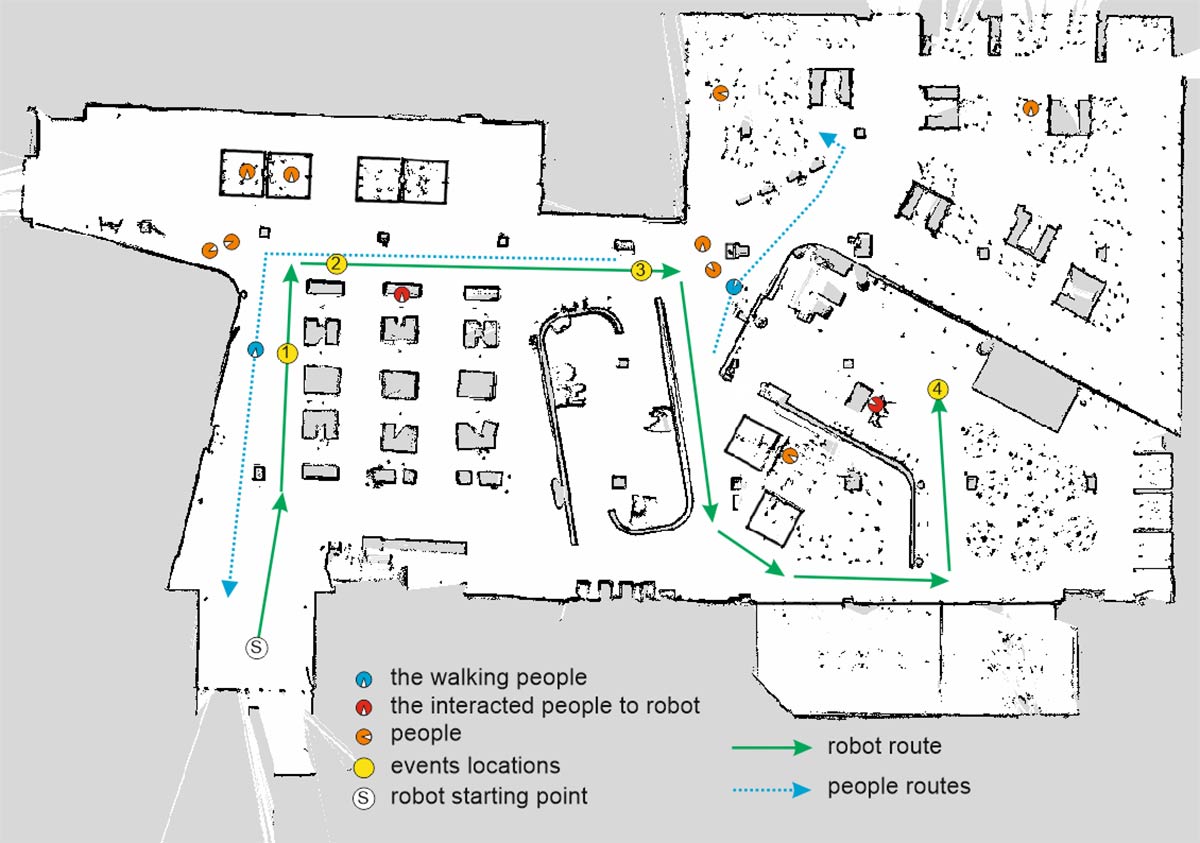
- Deployed the robot, mapped the environment, and supported user studies.
Tools & focus
UnityC#ROS 2User studies