Project notes
Telepresence robot simulation
A virtual test environment for robot navigation and user comfort.
- Discipline
- Robotics
- Context
- Research
- Period
- 2020–2021
- Support
- UniOGS Infotech
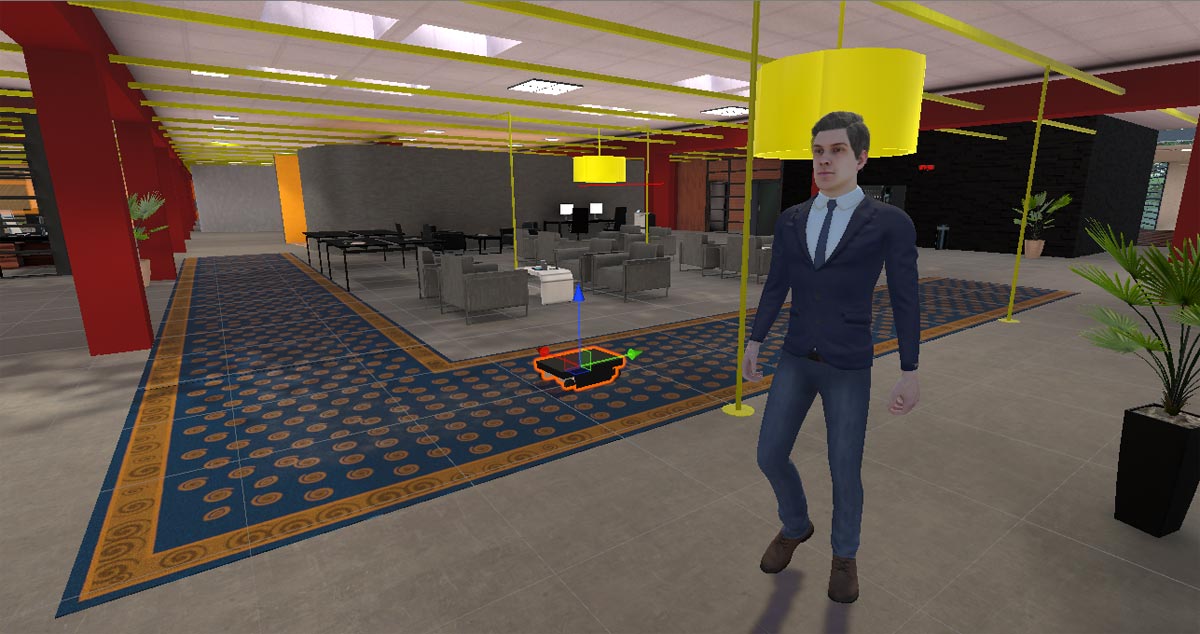
Tellus 1
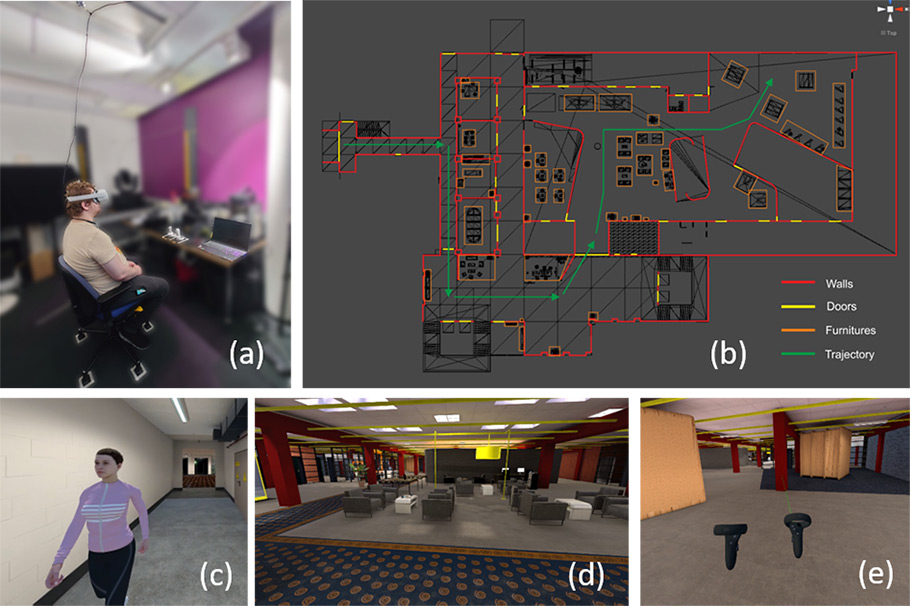
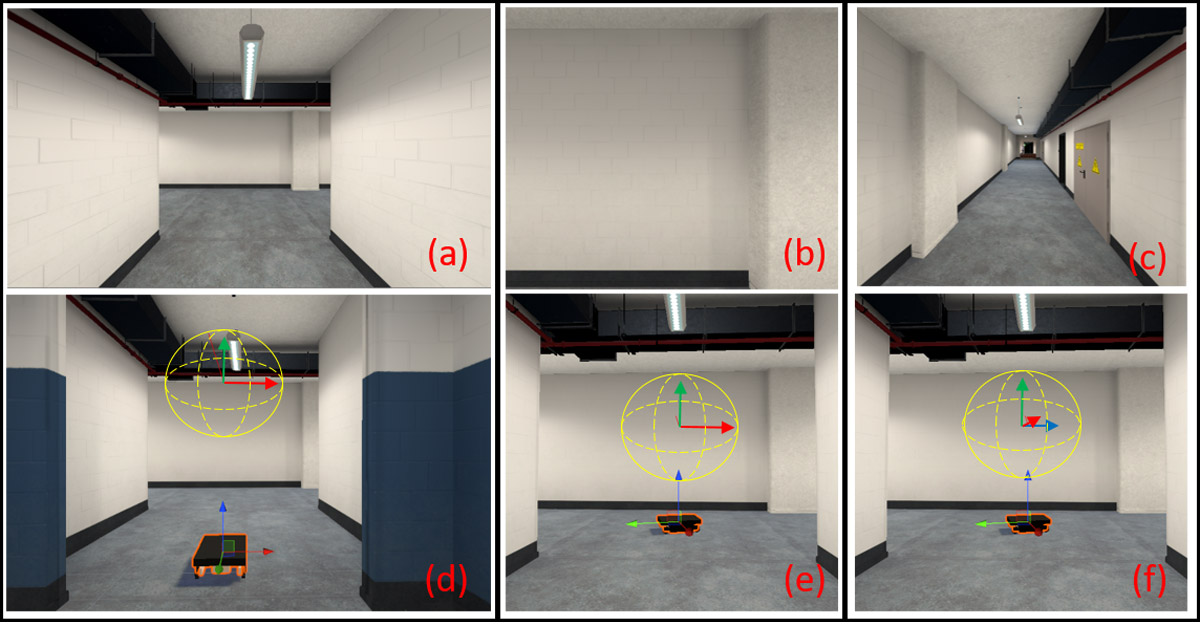
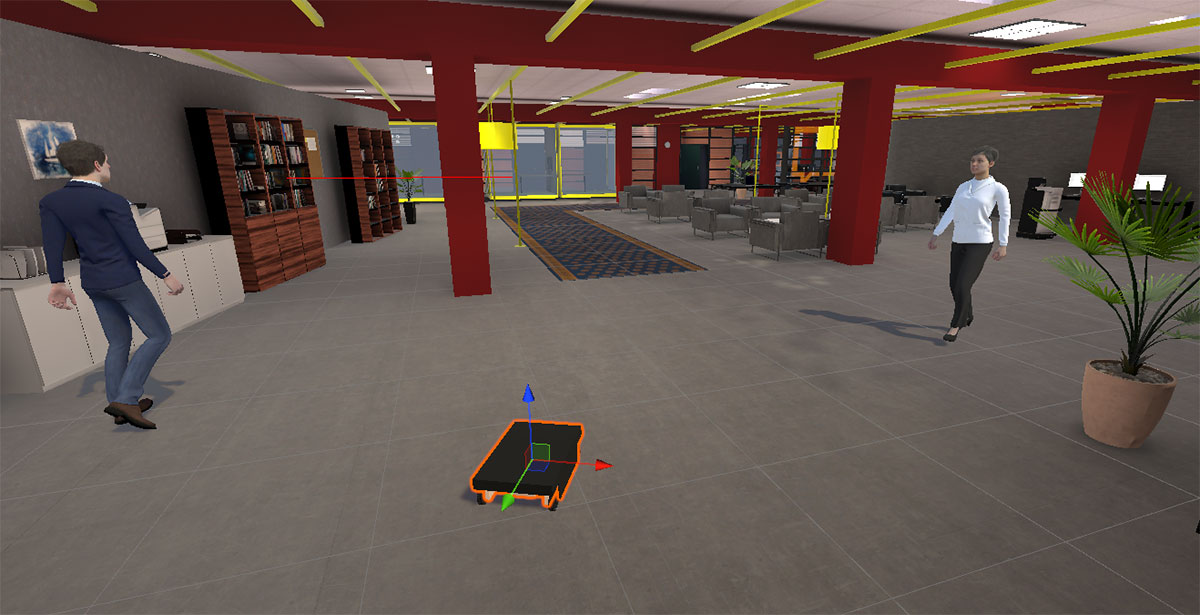
5 images · Select a thumbnail to explore. Original project photographs and illustrations.
The work
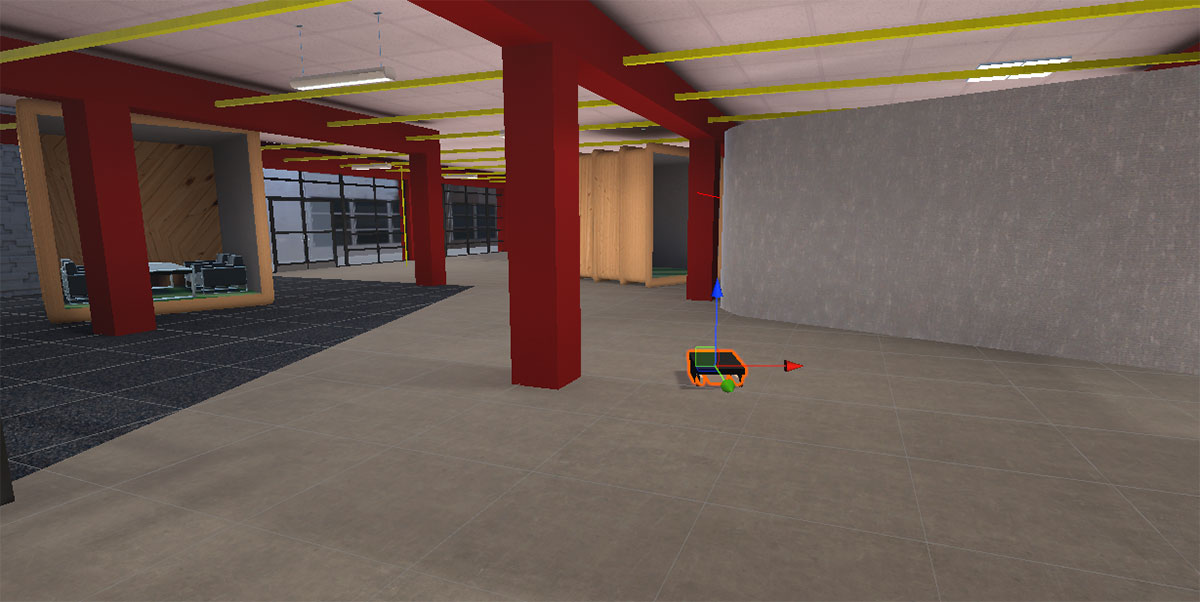
I developed a robot telepresence simulation using the Oulu campus virtual environment. It supported comparisons between unwound and coupled rotations before moving the research into a physical robot setup.
Project contributions & outcomes
- Connected Unity and ROS 2 across Windows and Linux using TCP/IP.
- Integrated DWB local planning and A* path planning for navigation and obstacle avoidance.
- Supported VR studies and questionnaires about comfort and the remote experience.
Tools & focus
UnityC#ROS 2Motion planning