Project notes
Multi-agent robot soccer vision
Coordinating two robots through a shared view of the field.
- Discipline
- Robotics
- Context
- Bachelor Thesis
- Period
- 2012–2013
- Support
- DIKTI-PKMP
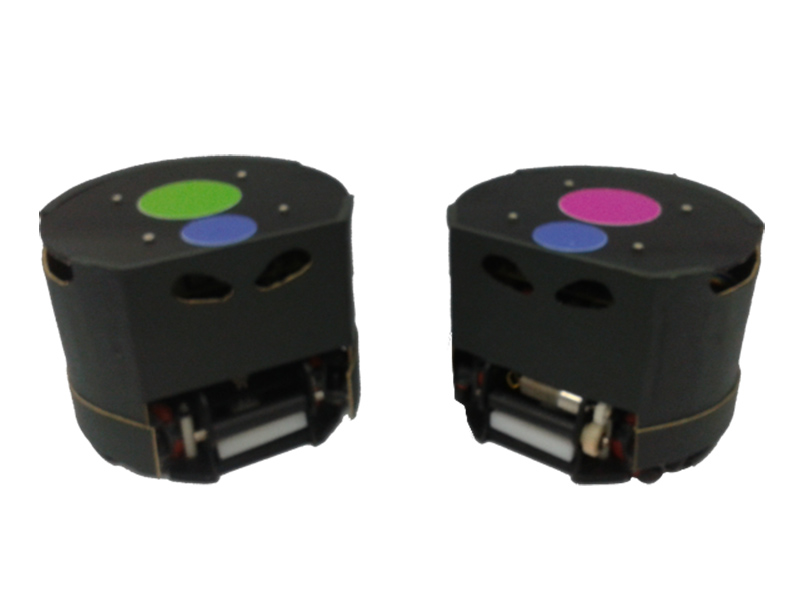
Twins

8 images · Select a thumbnail to explore. Original project photographs and illustrations.
The work
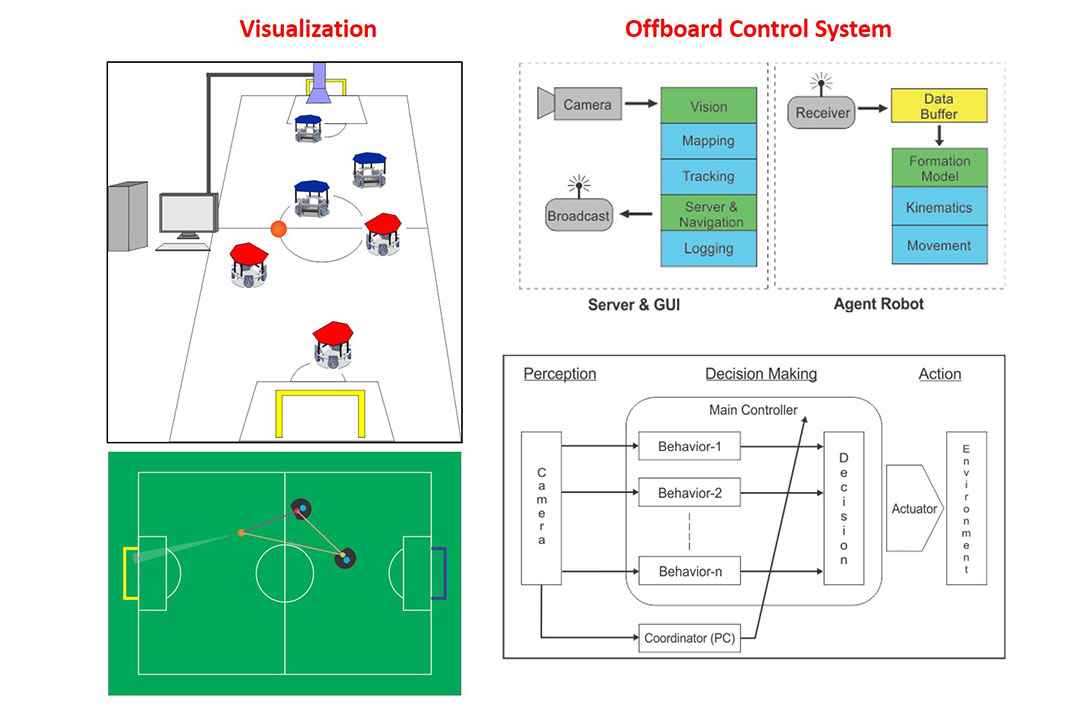
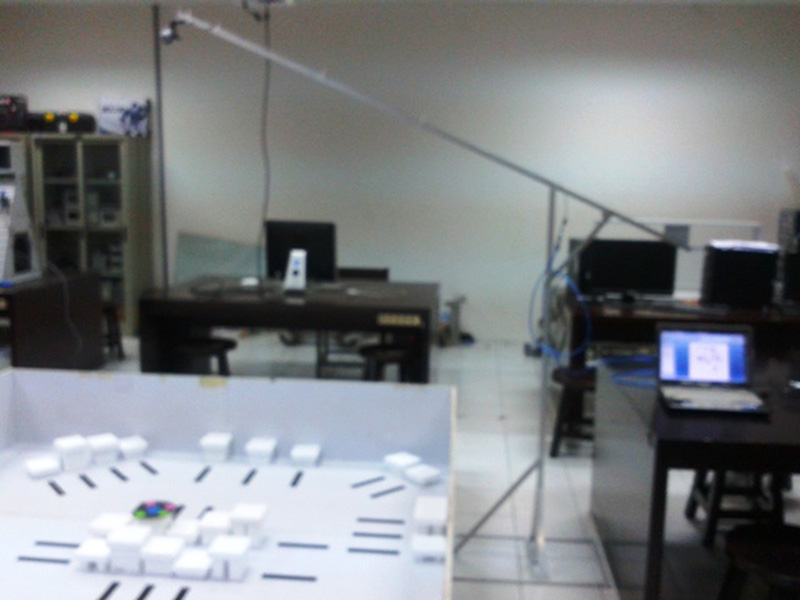
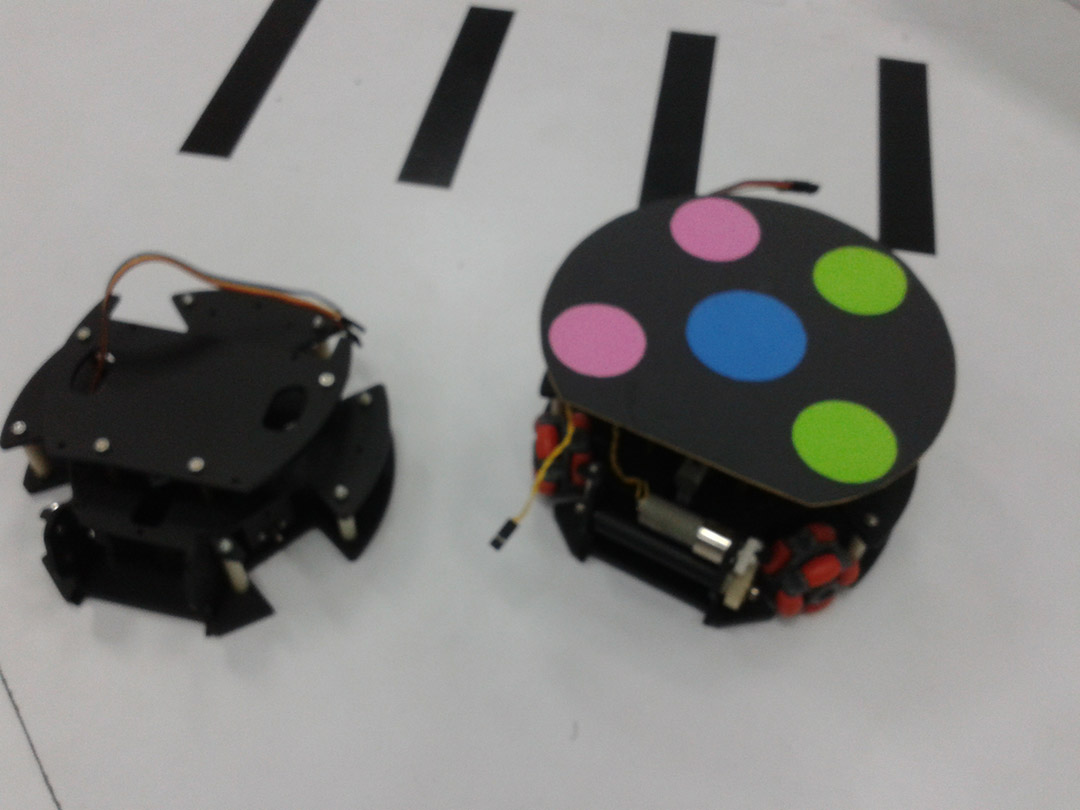
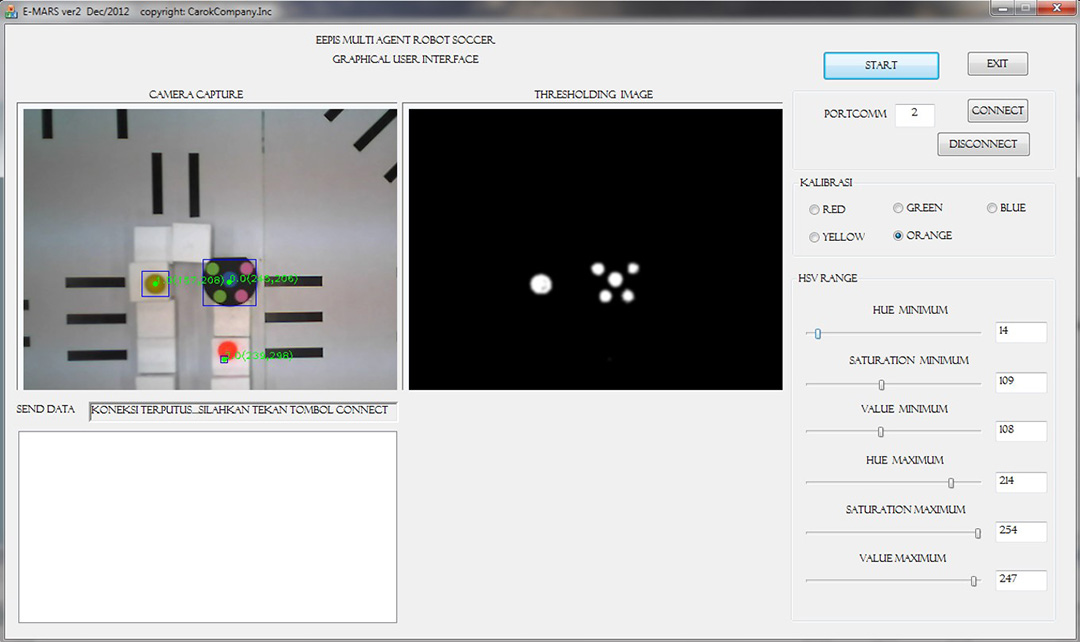
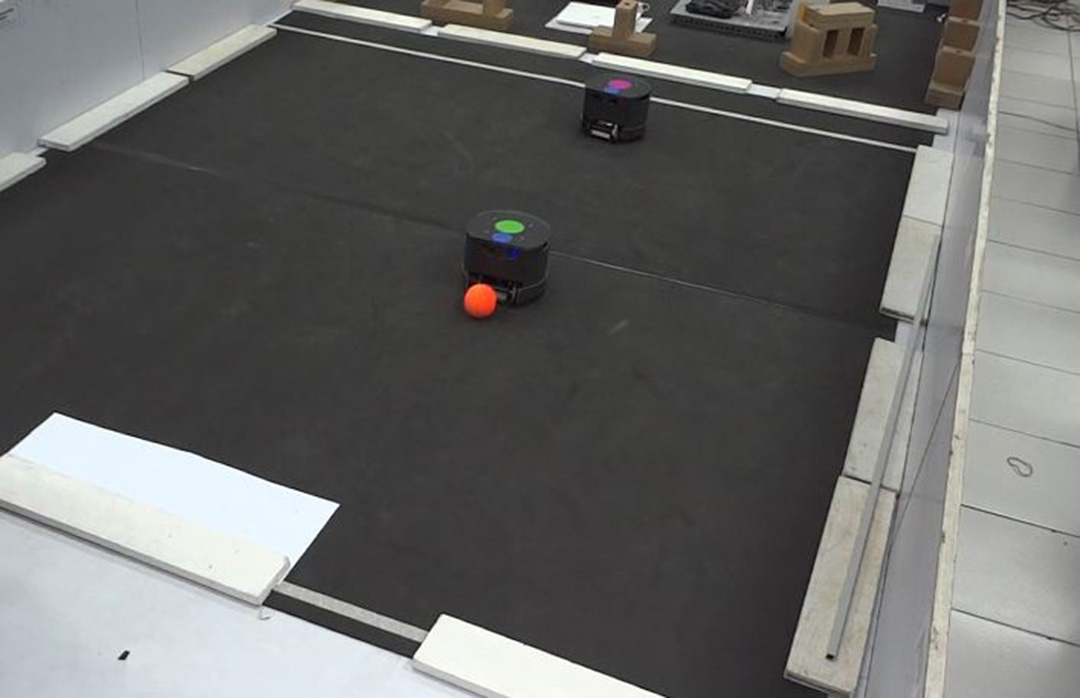
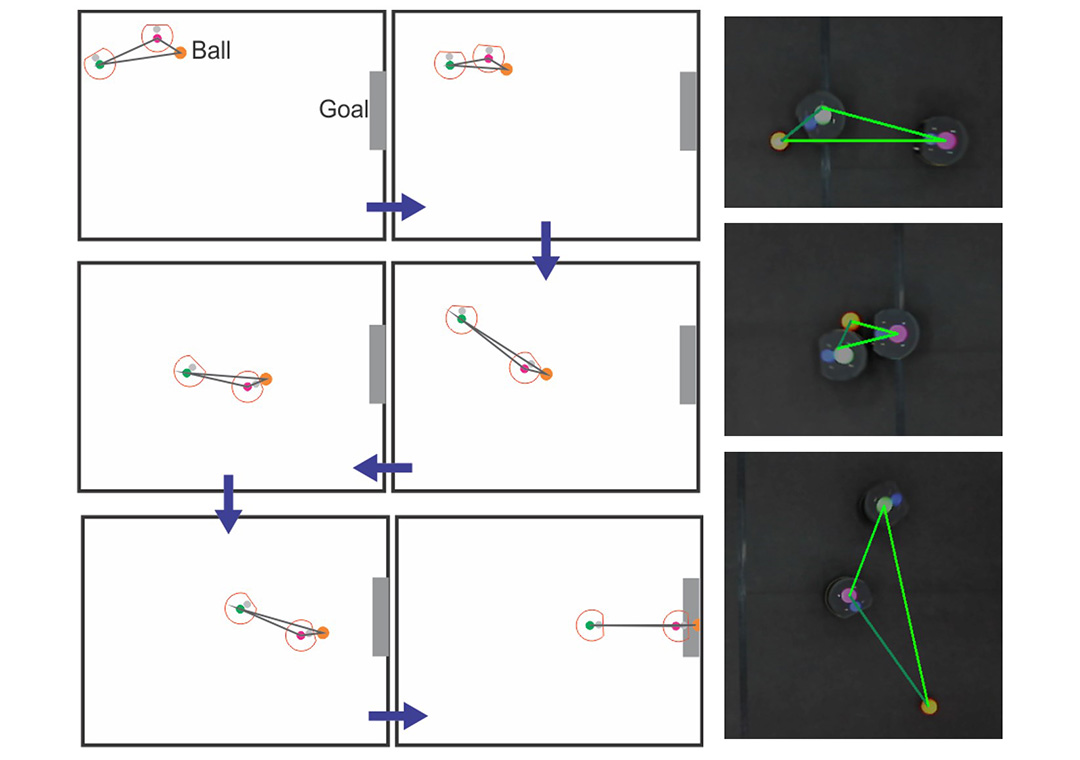
For my bachelor’s project, I developed a vision-based control system for two holonomic soccer robots. An overhead camera detected robots and the ball, while a leader–follower strategy selected actions based on each robot’s distance from the ball.
Project contributions & outcomes
- Implemented image segmentation, marker recognition, and ball detection.
- Built calibration and tracking interfaces for the vision system.
- Coordinated robot movement to find the ball and dribble toward the goal.
Tools & focus
Computer visionMulti-agent
systemsRobot soccer