Project notes
Validating inertial motion tracking
Comparing inertial tracking with encoder and optical measurements.
- Discipline
- Robotics
- Context
- Master Thesis
- Period
- 2015–2016
- Support
- MRL-Taiwan Company
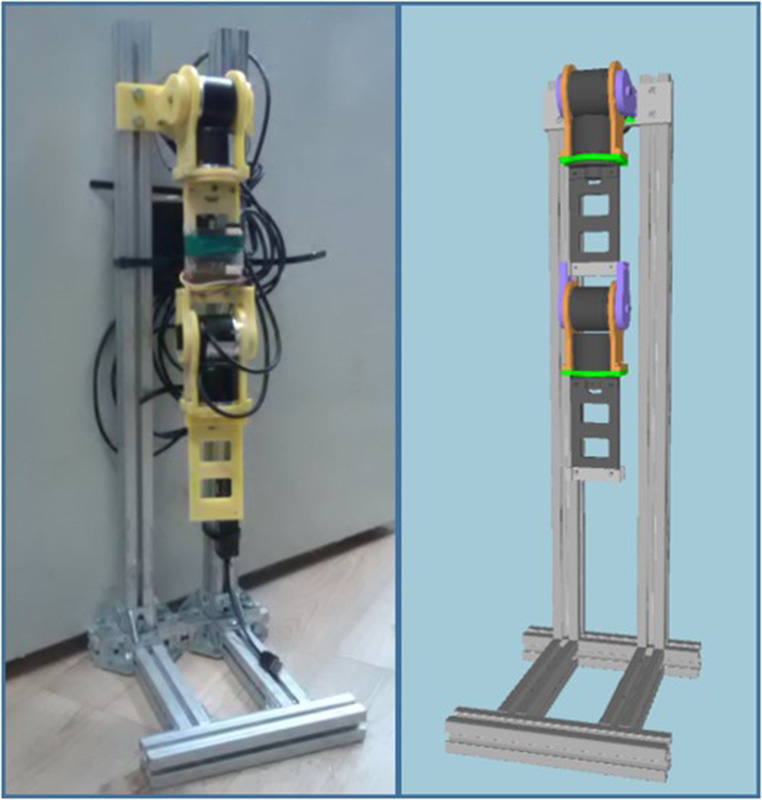
Encoder
6 images · Select a thumbnail to explore. Original project photographs and illustrations.
The work
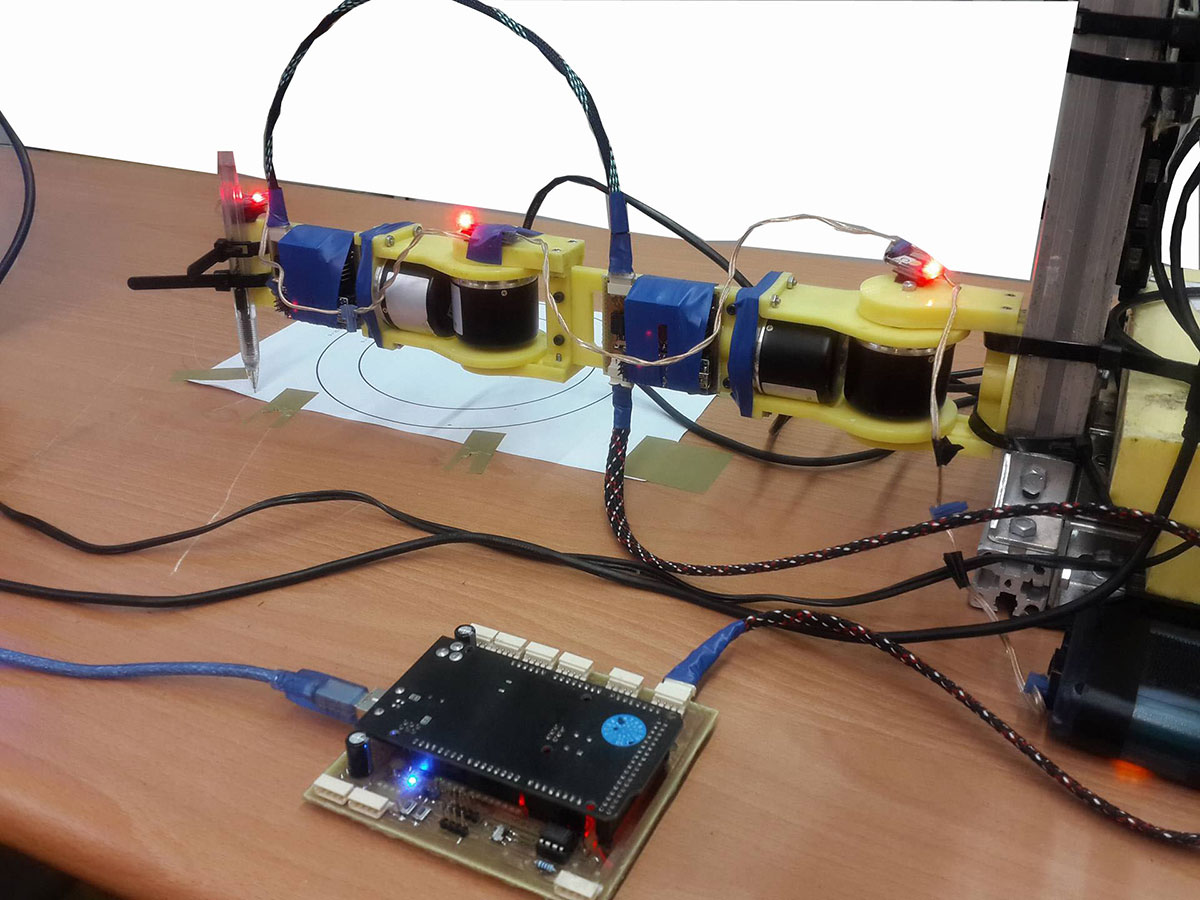
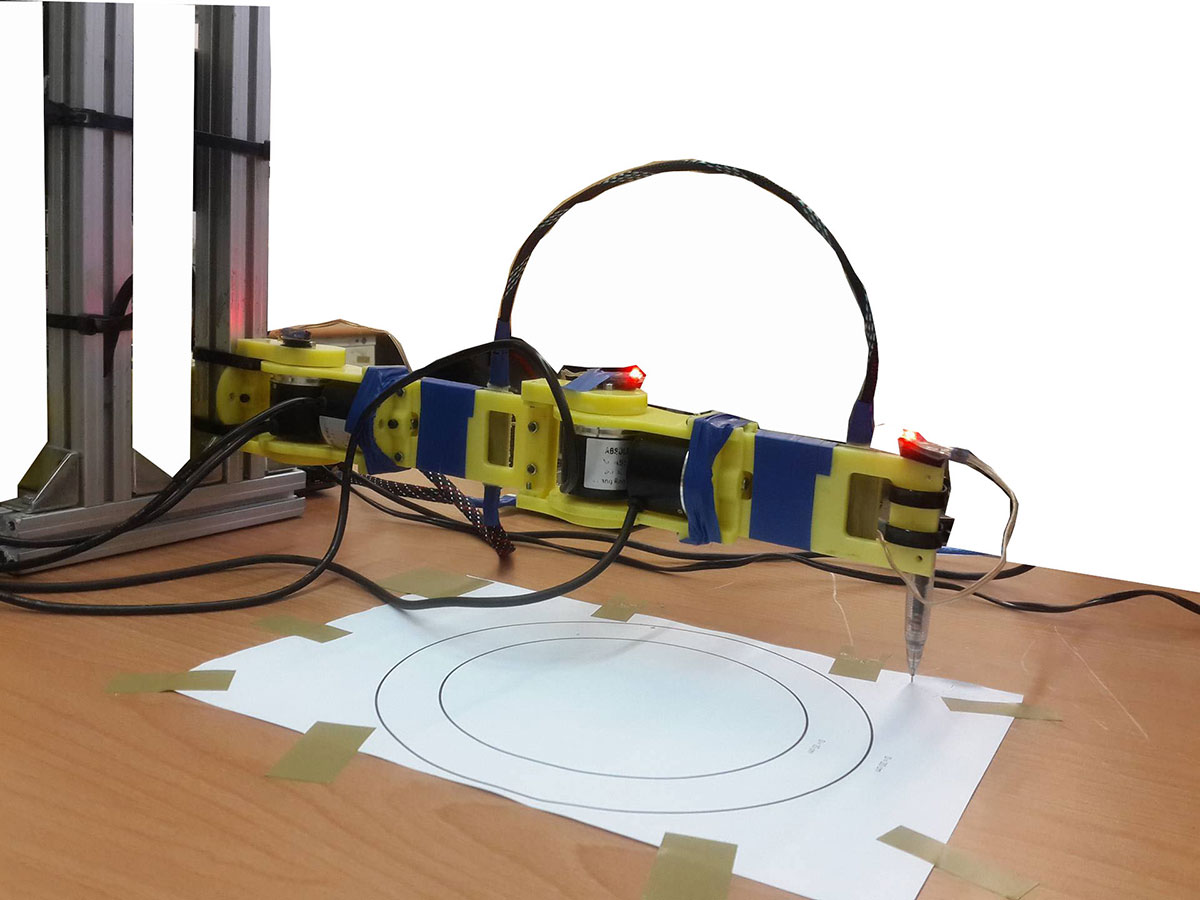
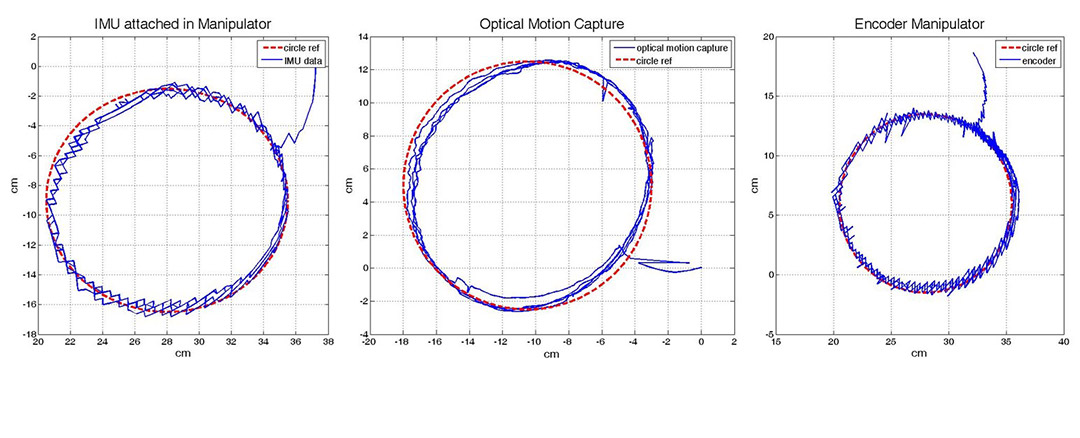
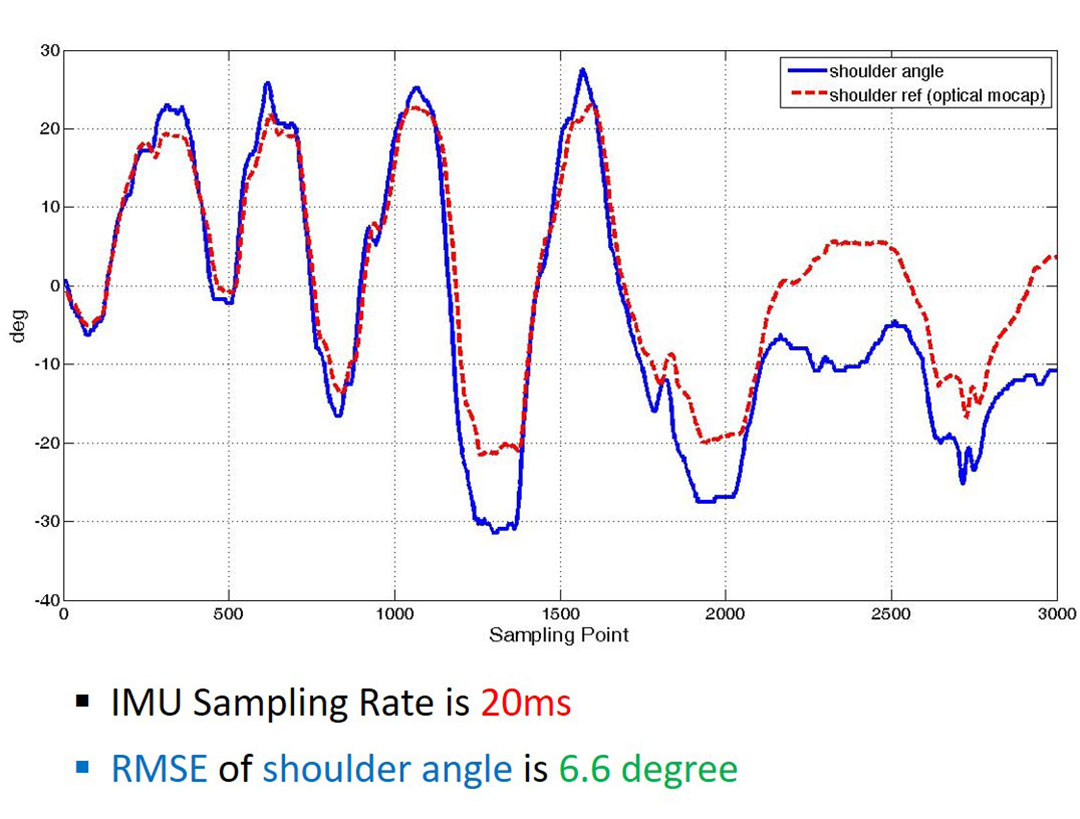
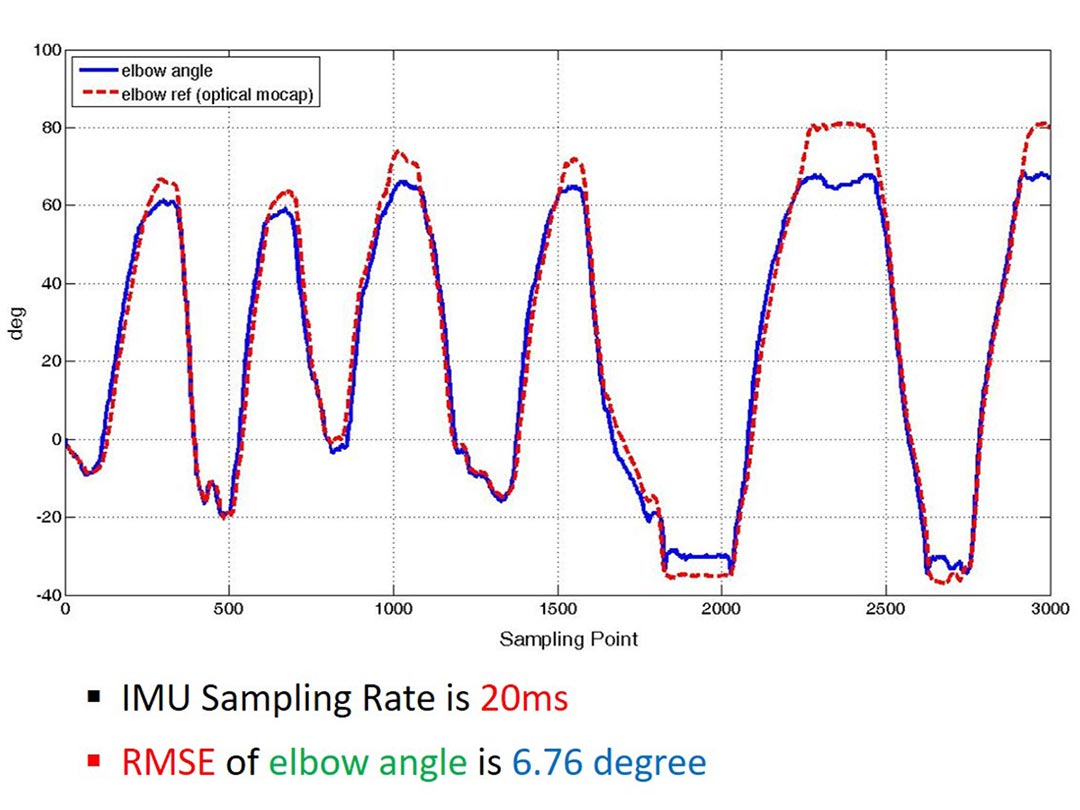
I evaluated IMU-based motion tracking using an arm manipulator with reference measurements from encoders and optical motion capture. The setup made it possible to compare tracked joint motion and the reconstructed end-effector trajectory.
Project contributions & outcomes
- Mounted IMUs on a manipulator to record shoulder and elbow motion.
- Used forward kinematics to reconstruct the end-effector position.
- Compared circular motion trajectories and reference measurements to assess tracking performance.
Tools & focus
IMUKinematicsMotion tracking